Demos
Practical prototypes in wireless localization, robotics, and embedded systems, connecting sensor integration with robotic control.
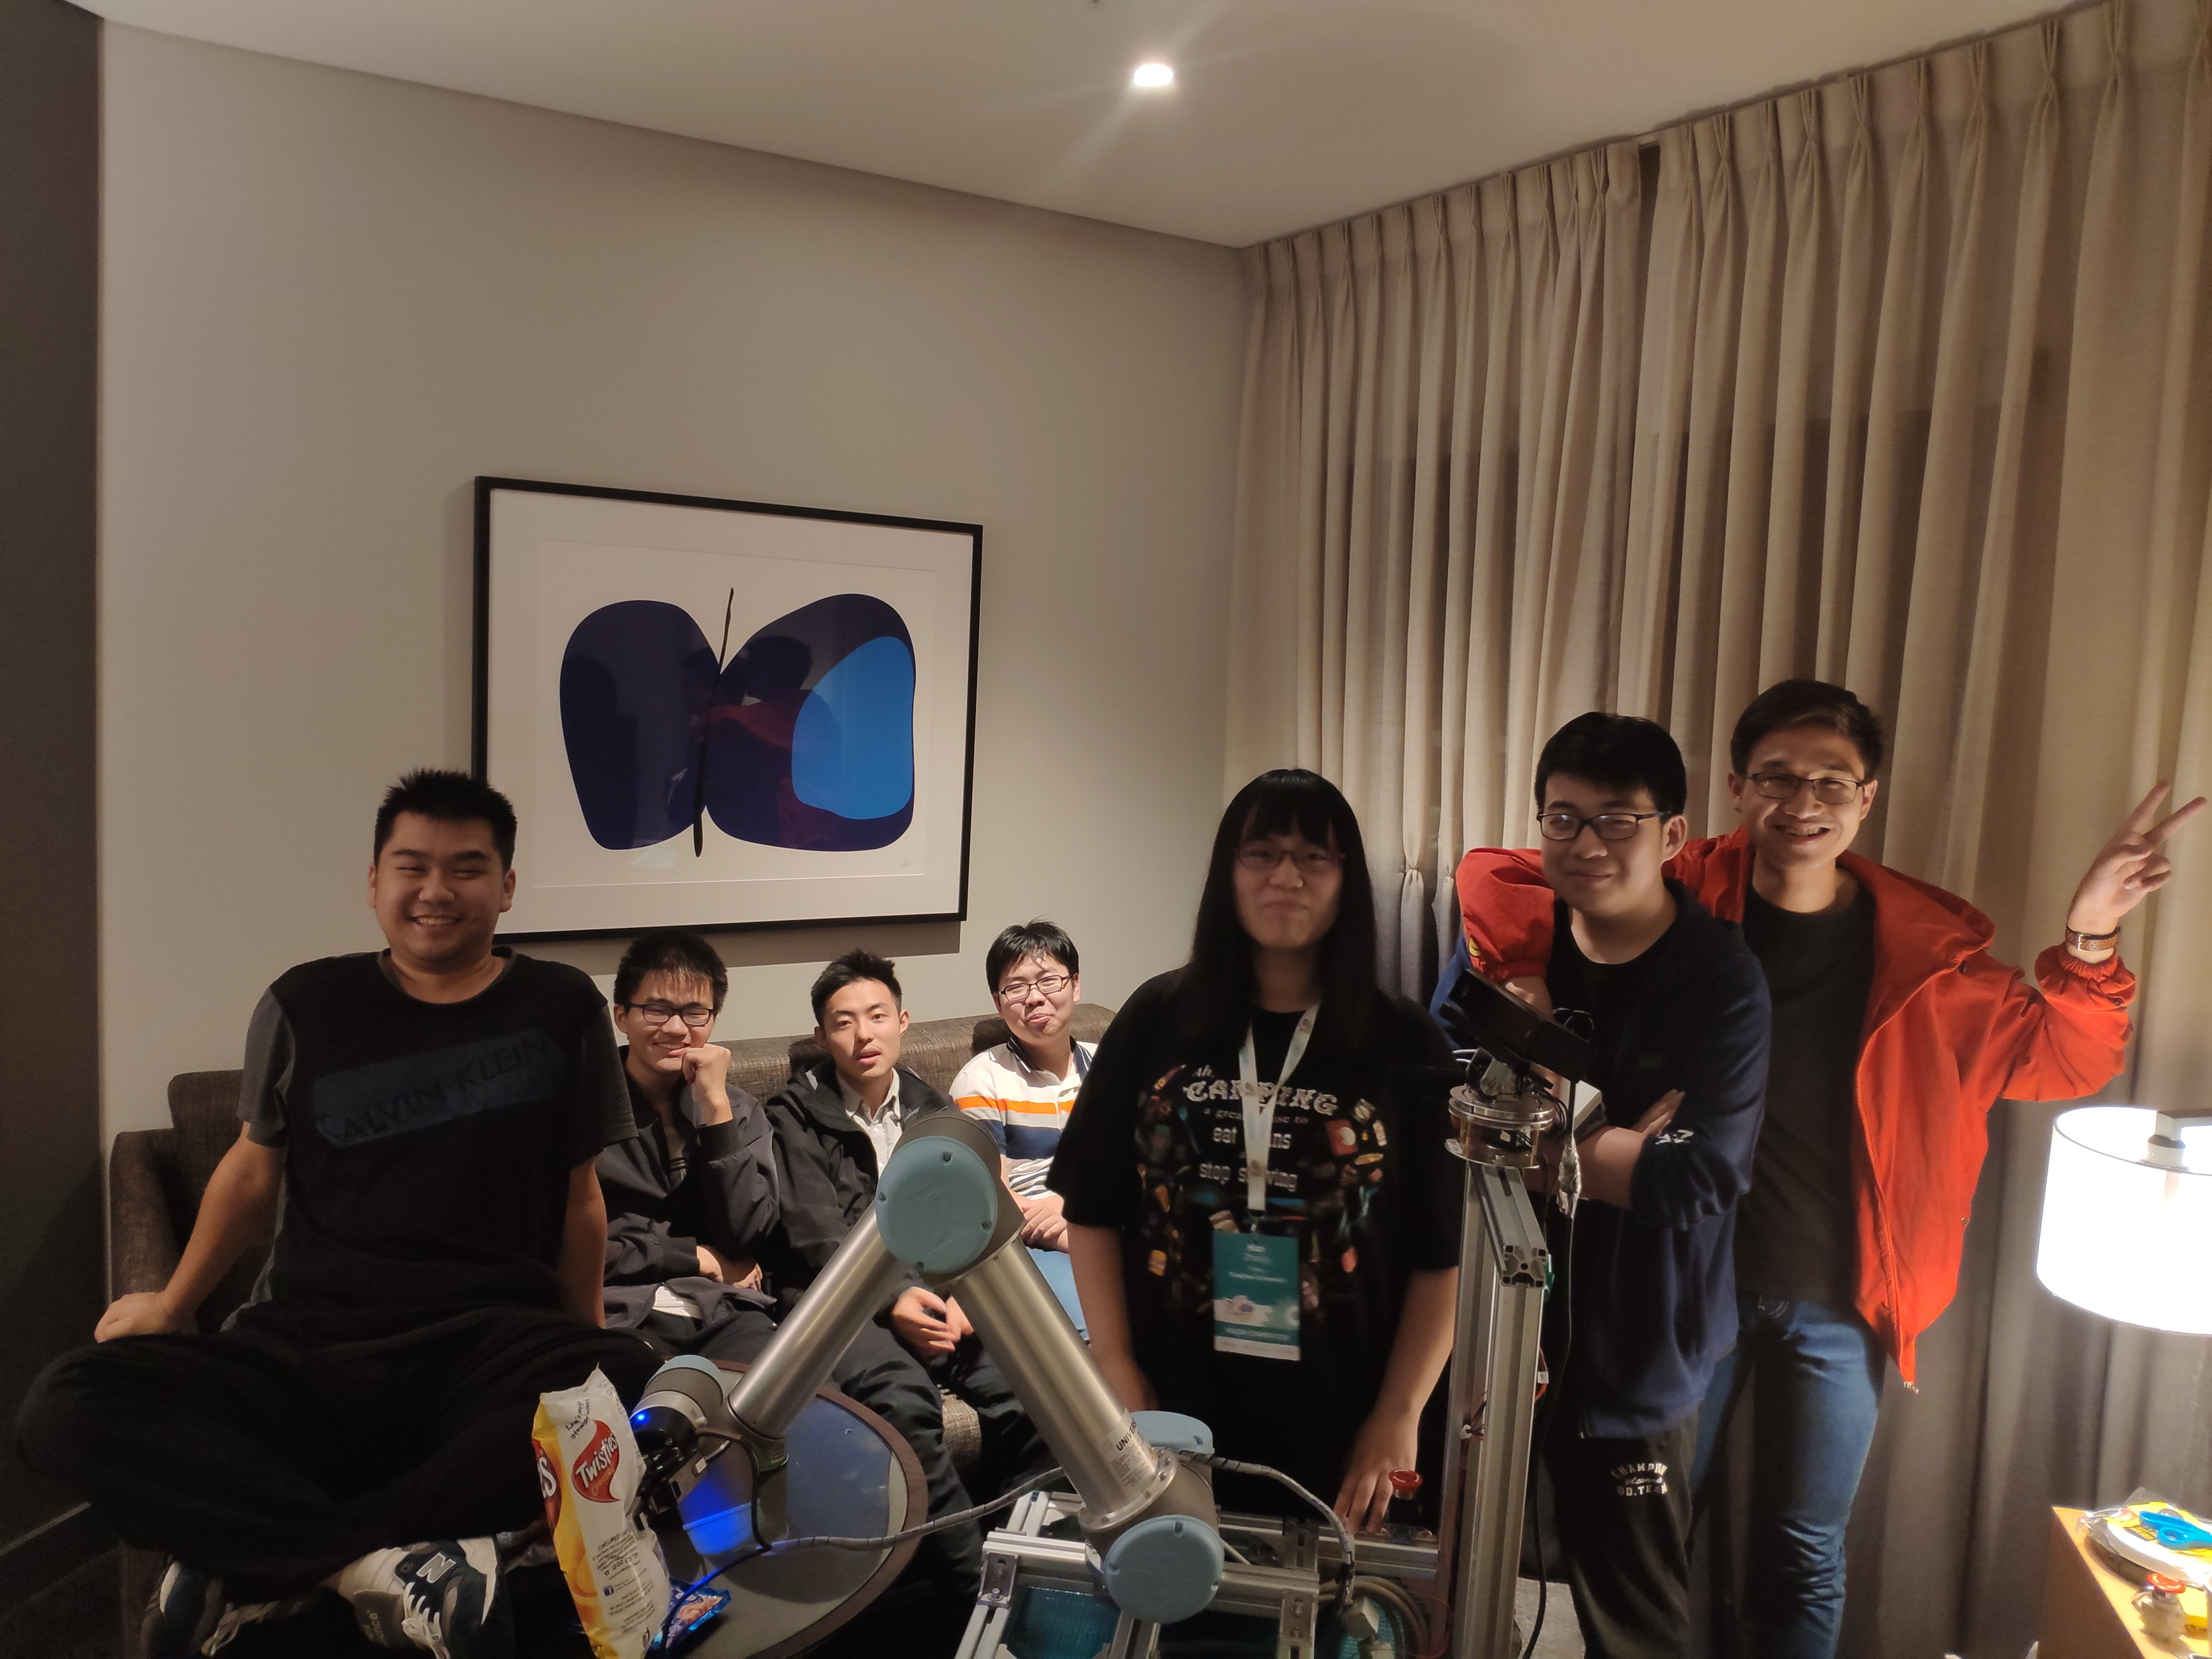
Alongside his research on physical-layer signal processing for 5G/6G communications, Zijian Zhang (second from the right in the photo) explores robotics through hands-on development.
His experience spans independently developed prototypes, collaborative designs, and extracurricular academic competitions, including RoboCup 2019 in Sydney, Australia.
Demo 1 UWB-Based Person-Tracking Vehicle
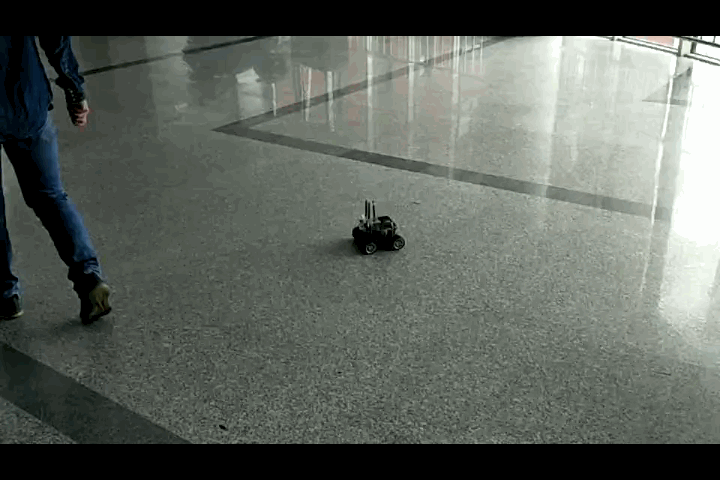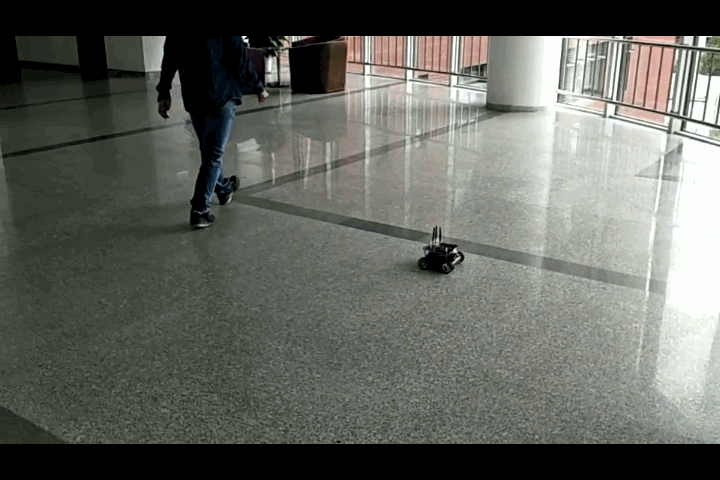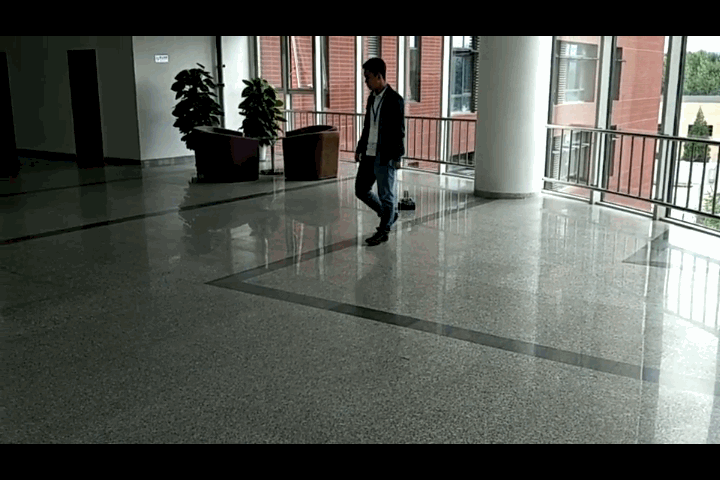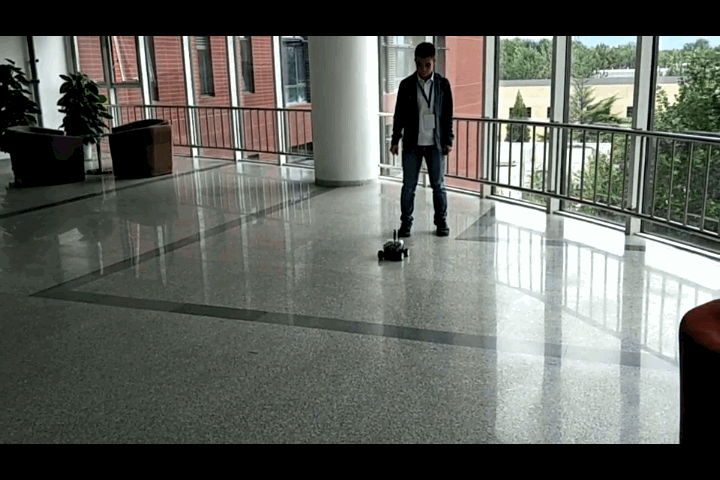
Designed by Zijian Zhang, XiaoXiang Li, and Tianyu Wang.
This small unmanned vehicle follows a person using ultra-wideband (UWB) localization. A three-antenna array, a Decawave DW1000 UWB transceiver, and an inertial measurement unit (IMU) form its sensing system.
The vehicle receives signals from a wearable UWB tag and estimates their direction of arrival (DOA) to track the wearer in real time.
Demo 2 Cooperative UAV Formation with UWB and Inertial Sensing
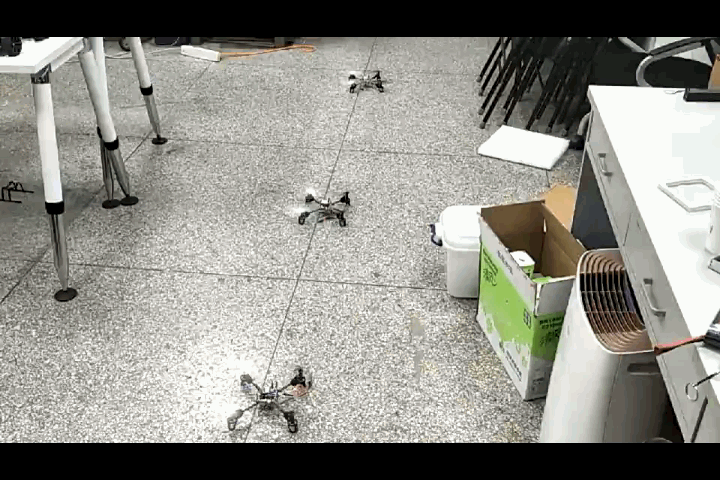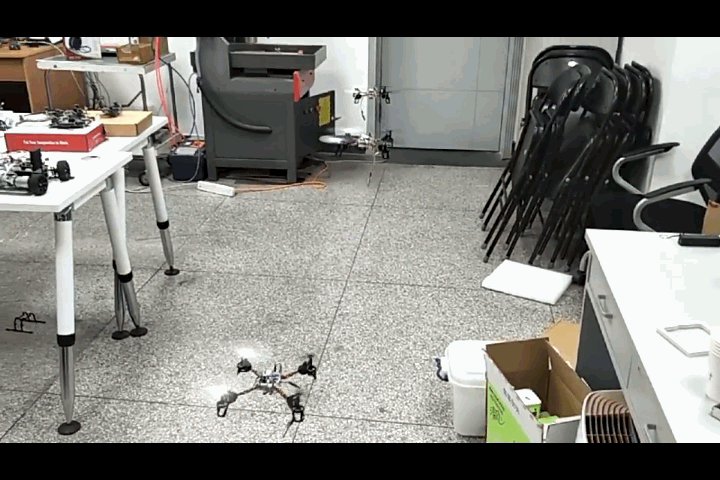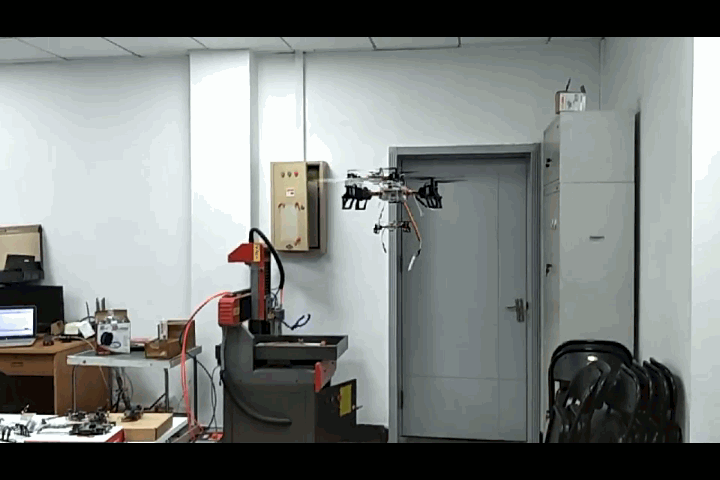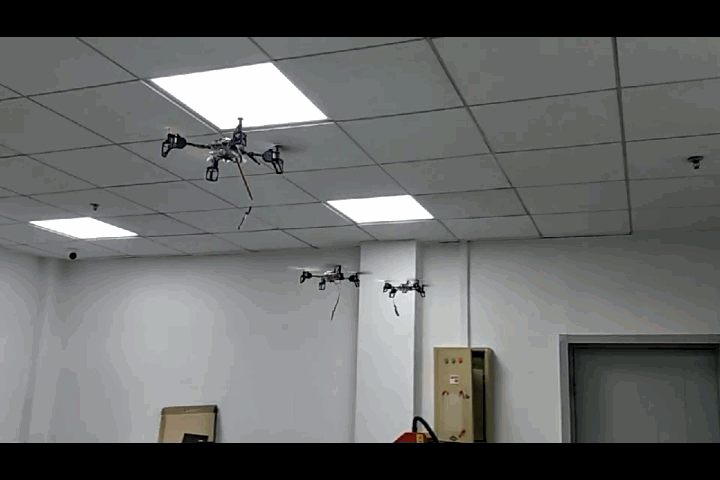
Designed by Zijian Zhang and Cuijie Xu.
This four-UAV prototype combines sensor measurements for cooperative localization and maintains the UAVs' relative positions in formation. Each UAV carries an IMU, a UWB module, an optical-flow sensor, and a barometer. An extended Kalman filter (EKF) fuses these measurements to estimate their positions.
The UAVs communicate over ZigBee. Any member can lead the formation, and each UAV can also be operated manually with its own controller.
Demo 3 Medical Robotic Arm with Wireless Control
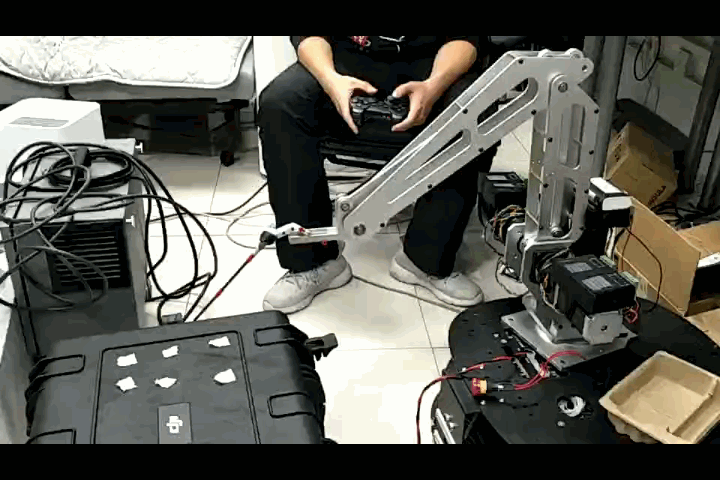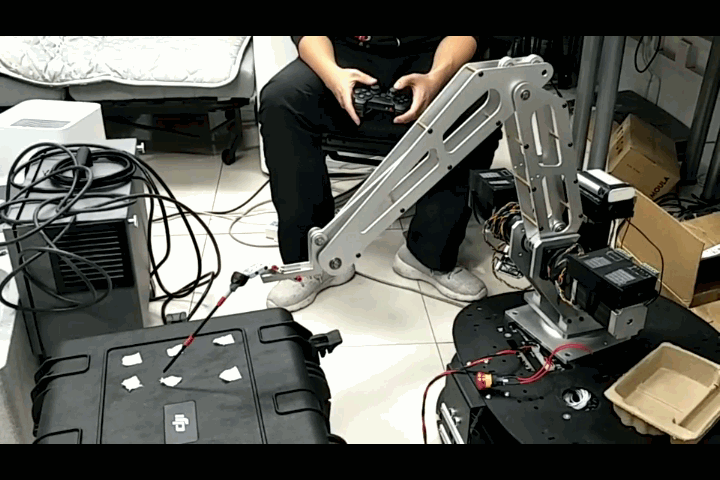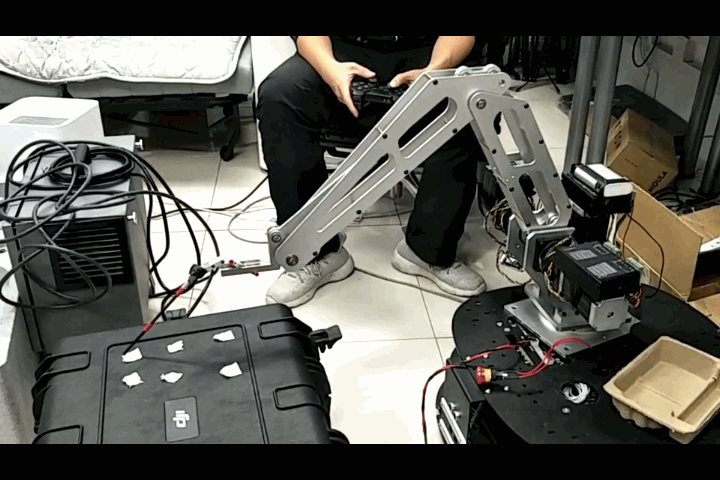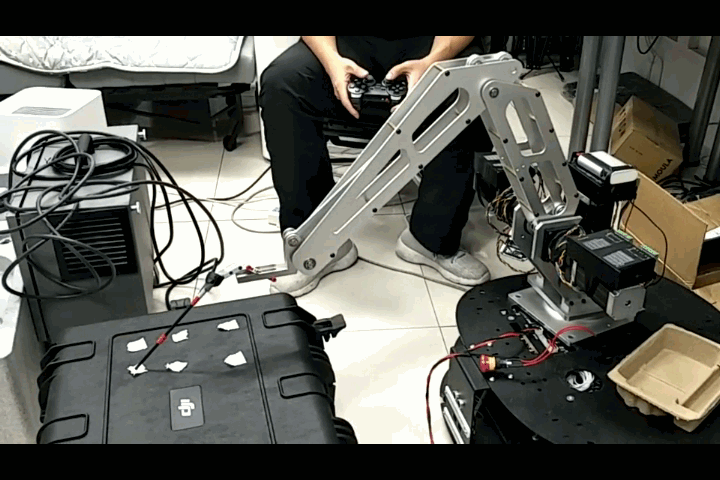
Designed by Zijian Zhang.
This flexible medical robotic arm supports programmed automatic operation and manual operation via a wireless controller. Zijian Zhang developed its mechanical structure, circuitry, and control software during his internship at EBOND in Beijing.
The arm provides centimeter-level positioning control. Its three high-resolution stepper motors are powered by a 48 V supply and controlled by an STM32H7 microcontroller.
Demo 4 Networked Sensor Node for Motor Fault Detection
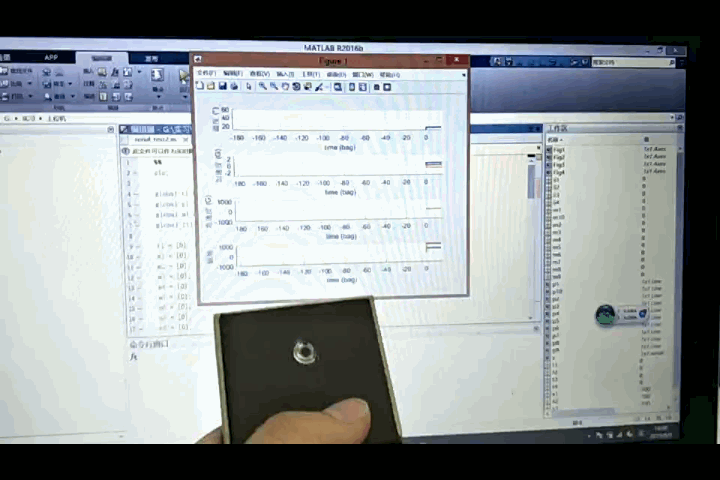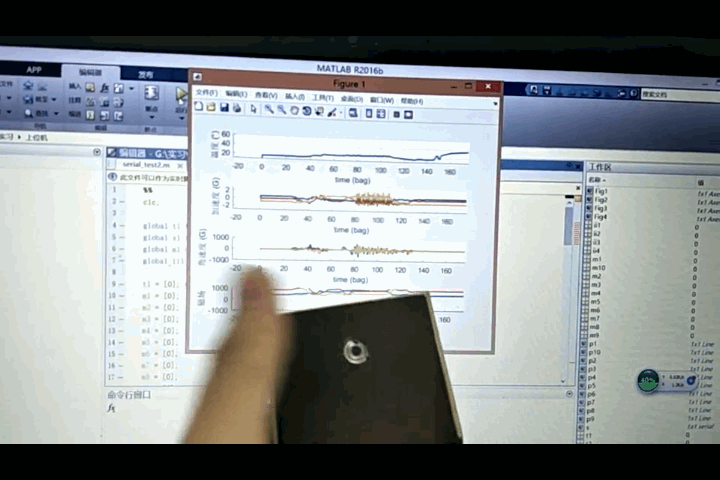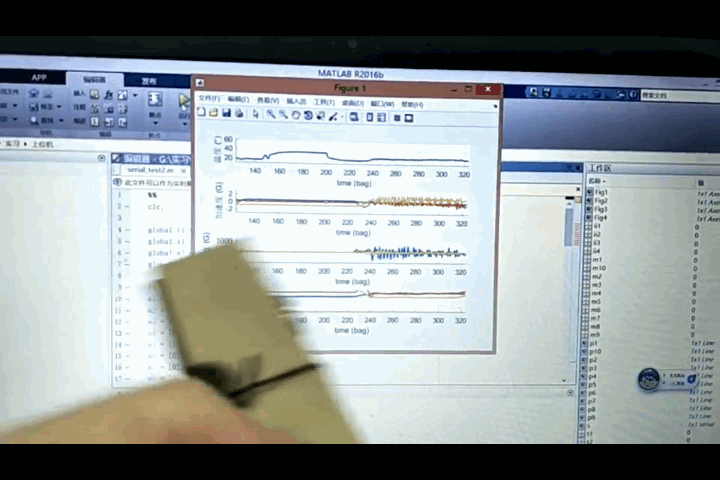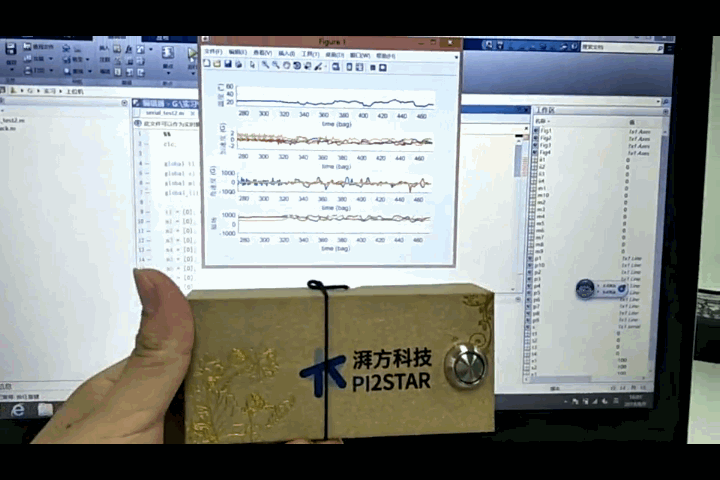
Designed by Zijian Zhang.
Developed during Zijian Zhang's internship at Pi2Star Technology Ltd. in Beijing, this networked sensor node collects measurements for industrial motor fault detection. It integrates an IMU with magnetic, infrared, and temperature sensors for use in an Internet of Things (IoT) system.
Mounted on a motor, the node transmits operating data to a host computer over Bluetooth for condition analysis.
Demo 5 Tinker Household Robot for RoboCup@Home
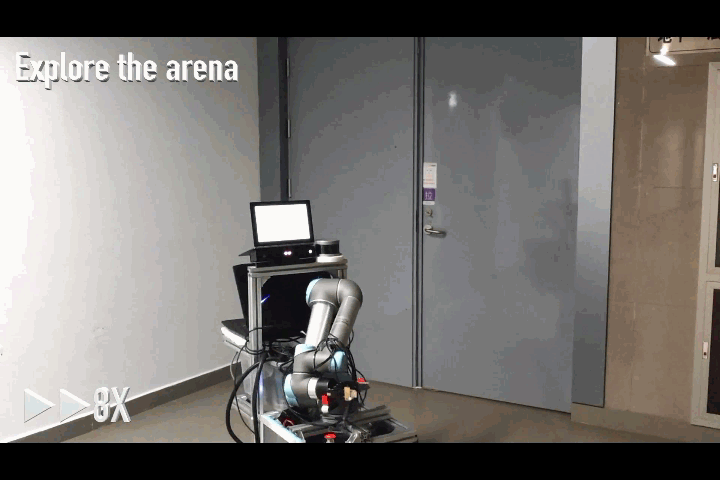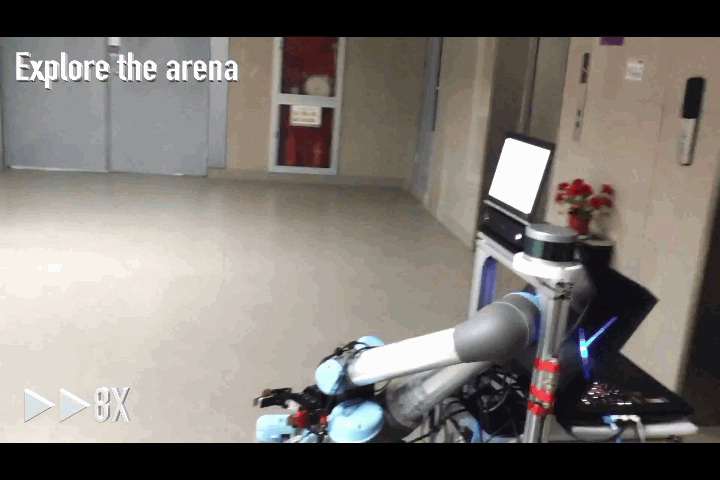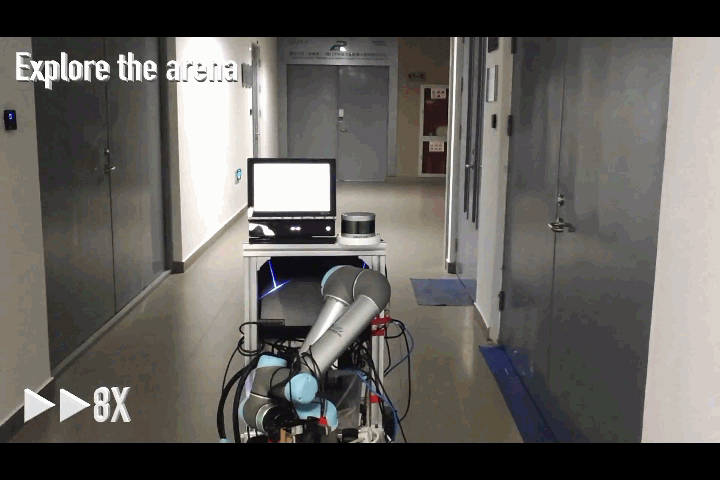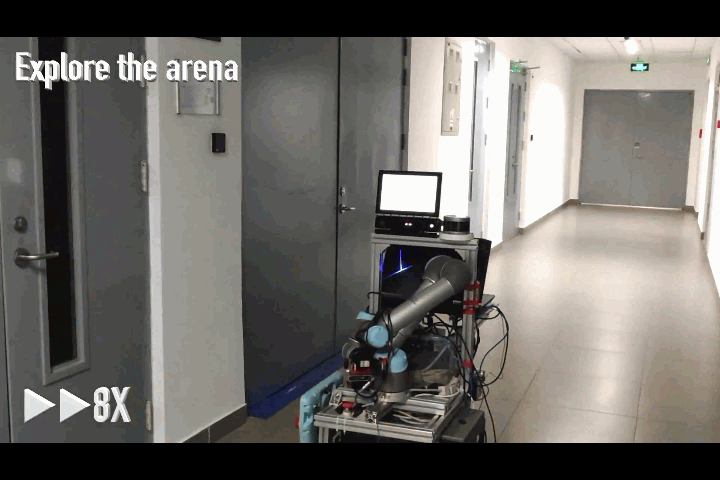
Designed by the Tinker team at Tsinghua University (team members: Jianghao Huo, Han Zhang, Lubin Ye, Haocheng Ma, Cuijie Xu, Zijian Zhang, Tengfei Zhang, Haitian Shi, Xinyu Han).
Developed for the RoboCup@Home 2019 Open Platform League, Tinker combines mechanical systems, electronics, and software created by the Tinker team at Tsinghua University.
The robot performs autonomous navigation and object manipulation in domestic environments and provides an interface for user interaction. The team description paper documents its hardware and software.